- [a]GaussianFormer: Scene as Gaussians for Vision-Based 3D Semantic Occupancy Prediction, ECCV 2024.
- [b]OccWorld: Learning a 3D Occupancy World Model for Autonomous Driving, ECCV 2024.
- [c]GaussianFlowOcc: Sparse and Weakly Supervised Occupancy Estimation using Gaussian Splatting and Temporal Flow, ICCV 2025.
- [d]GaussianFormer-3D: Multi-modal Gaussian-based Semantic Occupancy Prediction with 3D Deformable Attention, ICRA 2026.
Key Designs Inspired by Related Works[a–d]
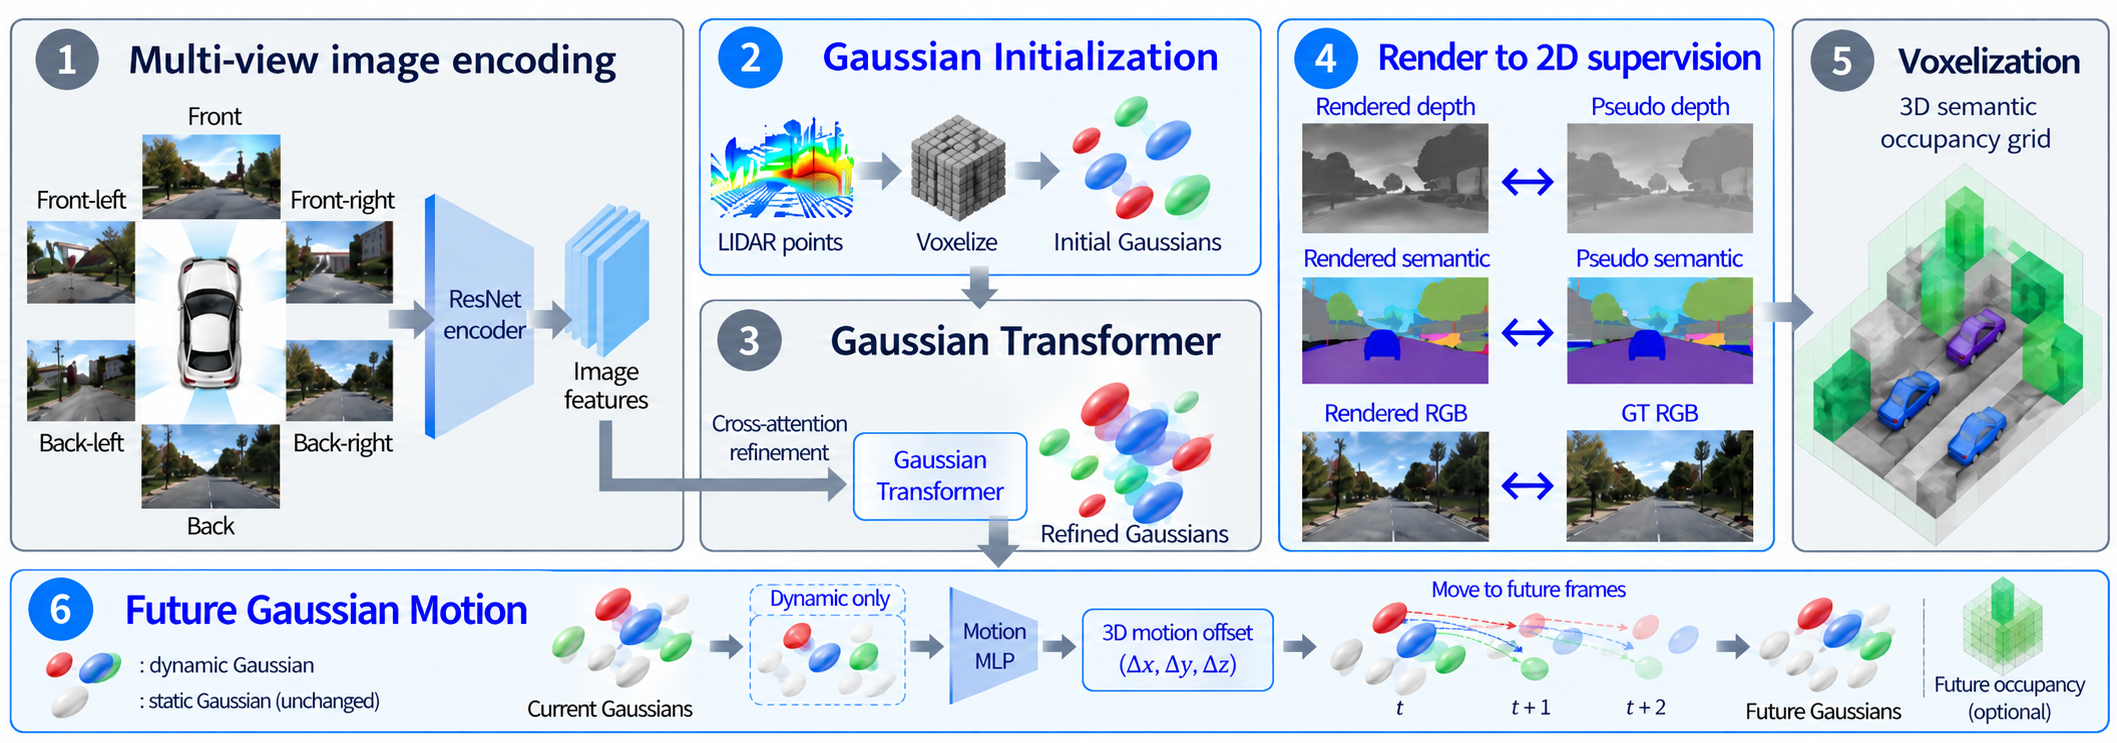
- Multimodal Gaussians (steps 1–3): LiDAR points and multi-view RGB images are combined to build the 3D Gaussians.
- 3D Annotation-Free (step 4): Gaussians are rendered to 2D and supervised with pseudo labels (no manual 3D labels).
- Future Gaussian motion (step 6): predicts future occupancy to support world modeling and long-horizon thinking.